Article Sidebar
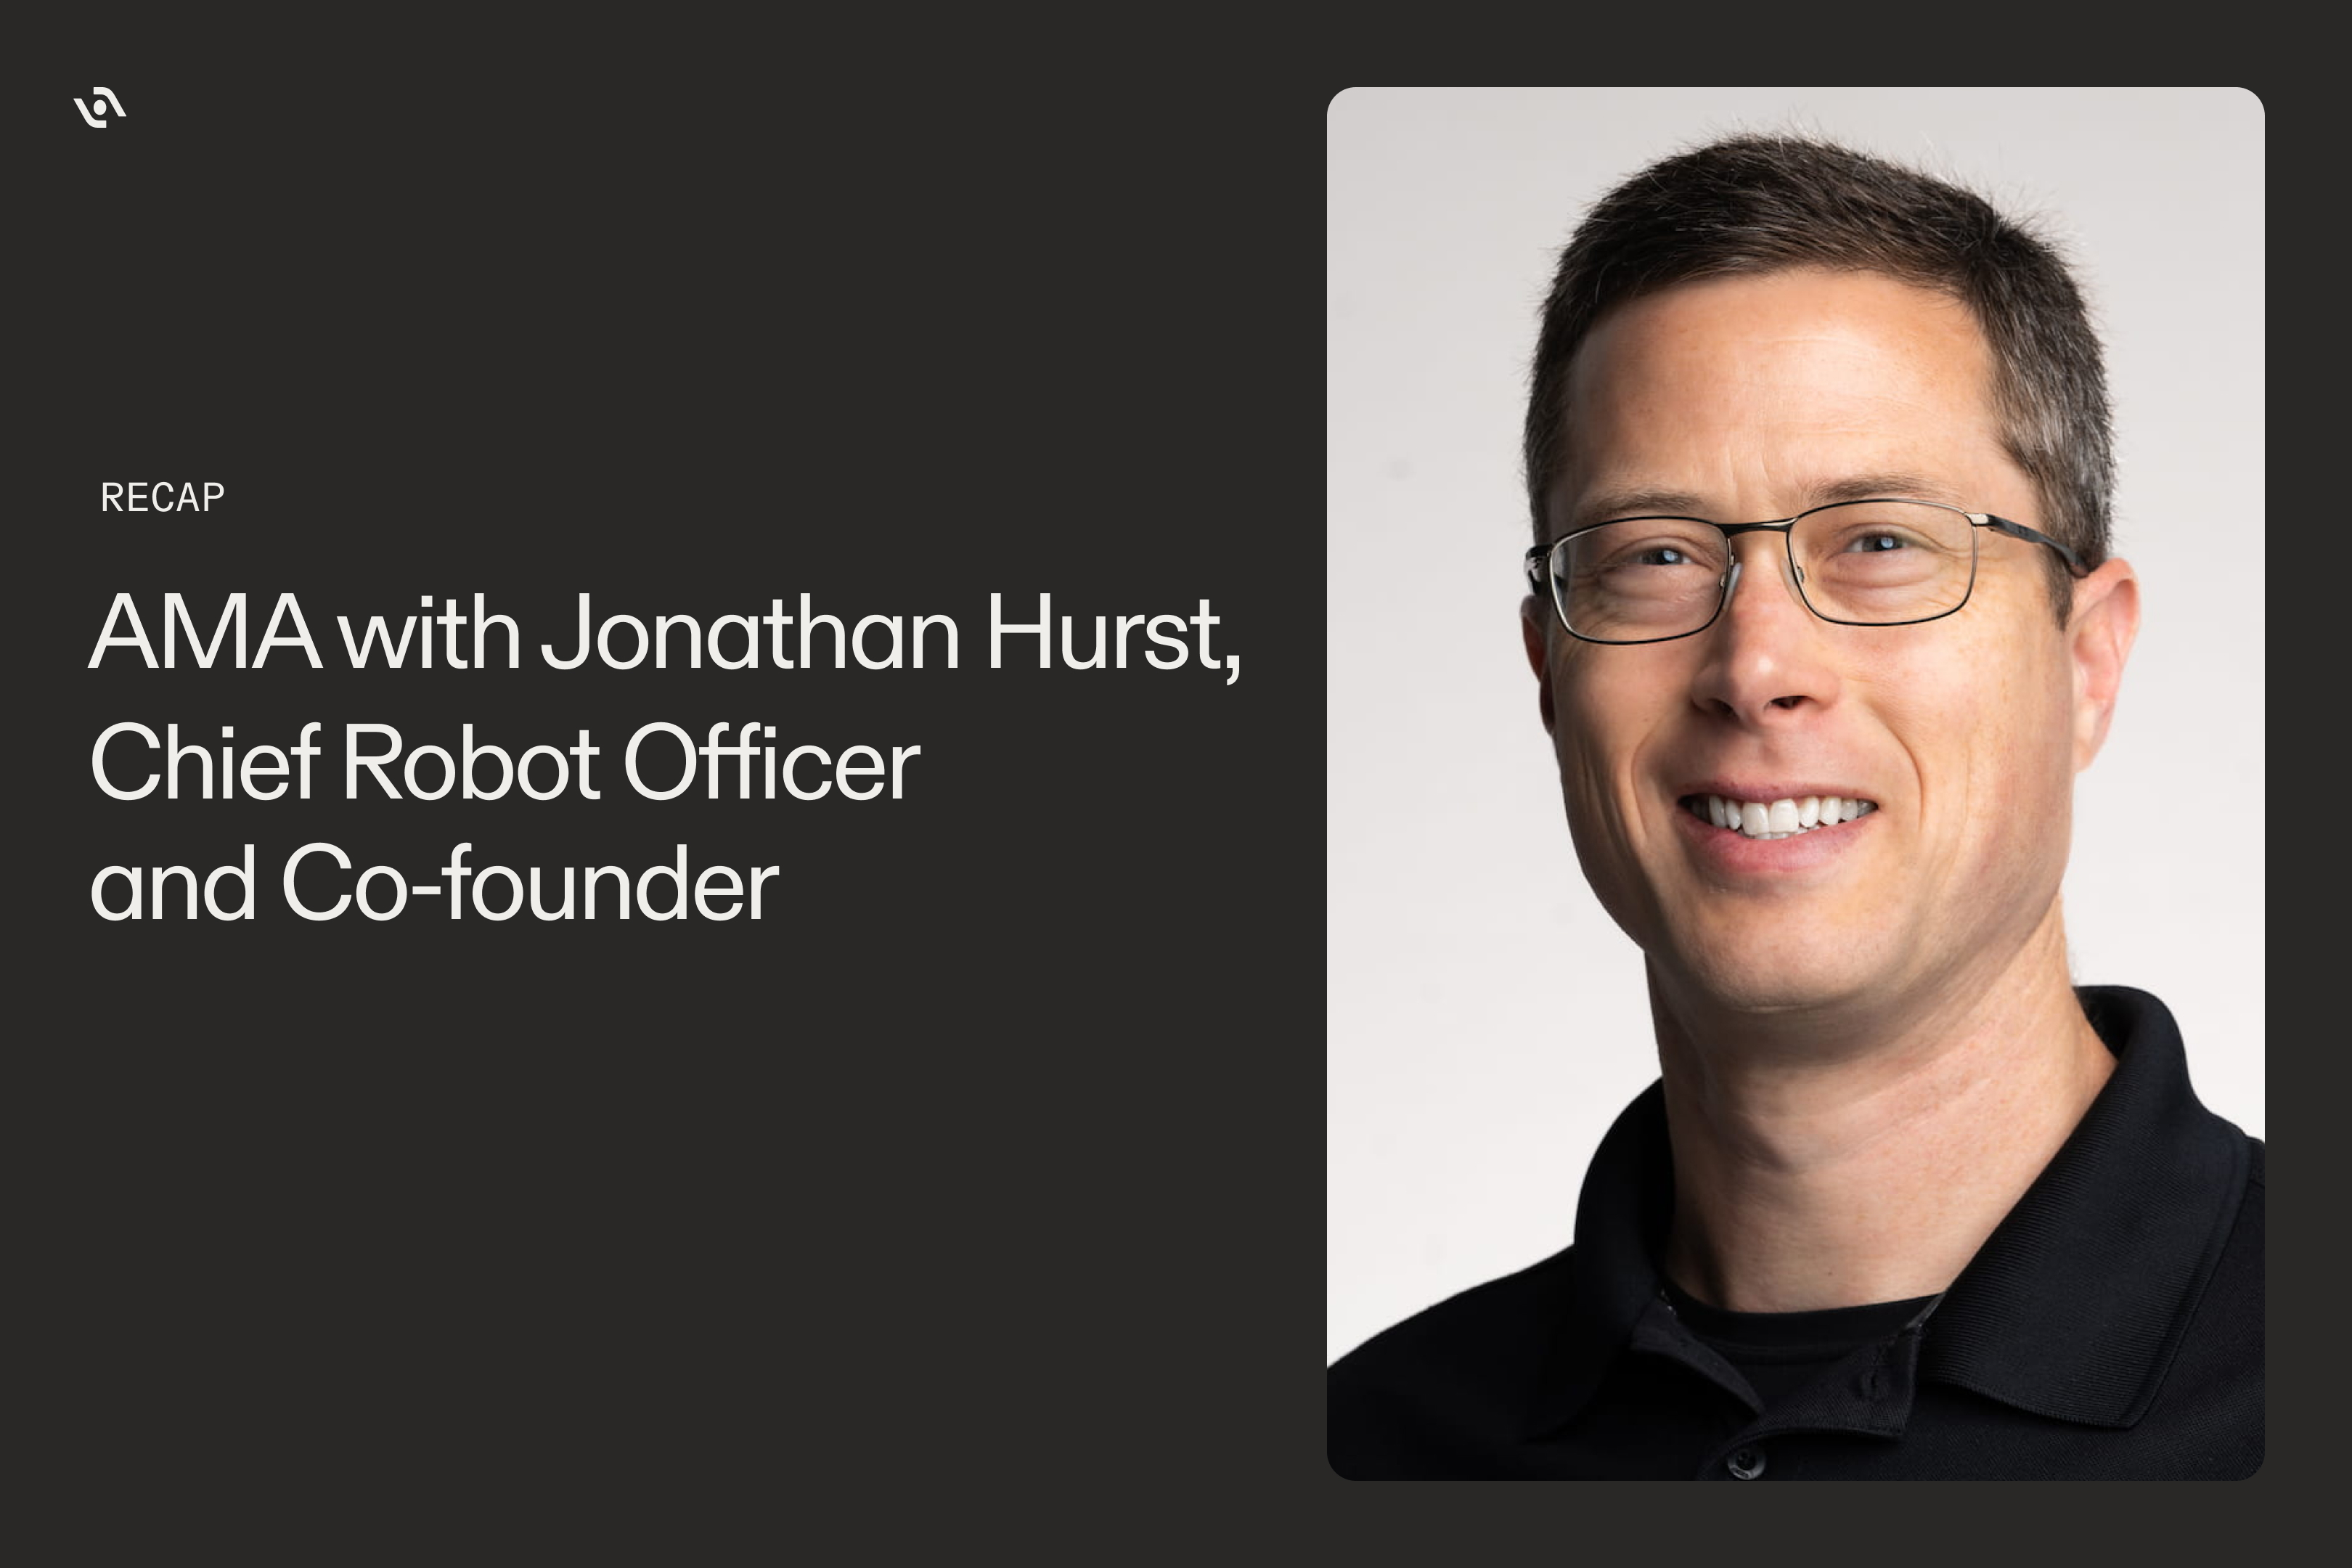
On October 22, 2026, Agility co-founder and Chief Robot Officer Jonathan Hurst spent an hour answering questions on X about the engineering behind Digit 5. Questions came in on X and LinkedIn from roboticists, engineers, and people who follow the work closely.
Jonathan answered 10 of them, covering safety, actuators, fleet calibration, batteries, and why Digit's legs changed. Here they are in the order he answered them, with his answers exactly as posted.
Asked on LinkedIn: What engineering challenge has been the hardest to solve as Digit moves from development to real world work?
Jonathan: The biggest thing that surprised us was safety. When we ran into that – it’s a hard blocker to deploy robots until we solve it. We had to design this entire system level safety strategy that just cuts through every single aspect of the robot and the process.
Making a 129 kg dynamically stable robot safe around people will touch nearly every part of Digit 5. The shape of the legs and body, safety-rated sensors in protective housings, isolated computers dedicated to safety, and AI-based human detection. Each of those will add weight, power draw and size, which is a big reason the robot grew. Until we did proof of concept deployments and tried to deploy robots with customers, we didn't understand the real scope of this challenge. It became one of the biggest technological challenges to solve. Now it will be integrated into the system, and we believe we have our arms around the problem. We understand what it takes to deploy these things. Now it’s about executing well in a system wide product level design.
Asked on LinkedIn: Jonathan, with Digit 5 moving to NVIDIA IGX Thor, how does that change the way Digit stops safely when it loses its network connection? Does more of that safety decision now happen on the robot itself?
Jonathan: It really doesn’t change much. The decision to stop is onboard the robot. Digit 5 will engage with our cloud software, Arc, which handles fleet orchestration and workflow integration, but a dropped connection won’t take away the robot's ability to do its task in the moment, nor will it affect any of the safety functions. The safety system is on an islanded computer, separate from the main control computer, and this independent safety system has relatively simple rules about what it’s allowed to do and verified from a safety point of view. If Digit 5 violates one of those rules, say in a certain part of a factory where it’s not allowed to raise its arm above a certain point, the safety system will observe it and shut it down. Before the NVIDIA IGX Thor, this was a completely separate computer in its own yellow box; but that islanded safety architecture is now going to be built into the NVIDIA IGX Thor and the Halos safety framework, which gives the onboard safety systems an industrial-grade foundation in a physically smaller footprint. Everything about safety is going to be onboard the robot and not reliant on any networked connection.
Asked on X: As Agility prepares to scale production and commercial deliveries, which technological advancements will be most important to accelerate this growth? And what engineering advantages do you believe will allow to stand out and maintain a competitive edge over other humanoids?
Jonathan: I’ve mentioned safety already. Solving that will open up our ability for Digit 5 to exist in many other parts of the facility where humans go. Manipulation capability really becomes the driver because the more things we are able to manipulate, move and handle, the more Digit 5 can do. The use case and applications expand. We can start with something reasonably well scoped like bins and totes because our prior deployments tell us that we can get to about 99% reliability when there’s a clear task and a clear manipulation for it.
Next we need to start doing item picking and making kits in our bins. We will then work our way towards cardboard boxes. The most important driver to do this is going to be the way that we do data collection with a deployed fleet of robots. We can have a whole data flywheel with high quality and directly relevant data to the use cases that we understand our customers need the most.
Asked on X: a) How does an existing model like Digit V5 adjust for improving compute (guessing there are physical weights / thermal limits to adjust for)? b) With the new battery needing only 9 minutes charging time, is there battery degration / thermal safety to adjust operations for?
Jonathan: The great thing about Digit 5 is that it will really be a platform for us where we can readily upgrade components and parts. Almost all of the compute will be contained in a box right up at the top of the torso at the top of the backpack. So as we want to upgrade and change, we can just change the compute box there on Digit 5 without really significantly changing the rest of the robot.
In terms of the battery, we've actually sized the battery and charging time for a battery that is already a year old and already operating in a really hot environment. As a result, when they're brand new we anticipate that they will be able to perform better than required. If the battery does start to degrade to the point where we're not getting enough life, then of course we can replace the battery, which is a fairly quick and easy procedure for us to do. But that is intended to be a regular maintenance process for the robot.
Asked on X: Question for Jonathan: how do you deal with robot-to-robot variation across a fleet? Calibrate every Digit individually, or train policies robust enough not to care?
Jonathan: Both. Minor variations exist in motor constant or robot component mass, that remain consistent once a robot is built, but may vary across the fleet; we believe these can be calibrated. But other features vary with time or temperature or other factors, and for those we must create policies that can handle the random variation. It is important to note, though, that one cannot train a policy to be robust to everything. We, as engineers, have to decide what is likely to vary, and be choosy about what we require the policy to be robust to; mostly, that should be things that will be outside of our control, like ground height, or mass of a bin, or friction coefficients.The more robust a policy is, generally, the lower the performance. For example: If we truly have no idea what the ground friction will be, then the robot always has to walk as if it were walking on ice. If we do have some confidence in the range of uncertainty of the ground friction, we can increase our confidence appropriately for the robot performance.
Asked on X: Reflected inertia always shatters kinematic idealism. Warehouses don't care about sleek CAD renders if high-ratio gearboxes lag on sudden heel strikes 🍏 Defend Digit 5's tradeoff: pure compliance or raw payload?
Jonathan: For physical interaction with the world, we believe Digit 5 will need to move in a fundamentally different way from traditional position-control robots, and instead more like the way animals move. Meaning with exceptional force control and compliant interactions with the environment. One way to achieve this is “transparency” in the actuator, which means basically that you can get whatever force you want from the actuator instantly. But this is an impossible task. Two major things that get in the way of transparency are reflected inertia (the spinning rotor going very fast behind the large gear reduction, which then feels like a huge rotational inertia on the gearbox output) and friction in the gearbox, which can be quite large for some technologies. To achieve best possible transparency, people use very low gear reductions, usually quasi-direct-drive with planetary gears. But you cannot achieve high torques this way. For a robot as large as Digit 5, which will have 50 lb lifting capacity, quasi-direct-drive is not really feasible and we must have higher gear reductions. We will do this with our proprietary cycloidal transmissions, which will achieve better efficiency and eliminate the friction as a problem so we can control our torque very effectively using the current control of the motor windings. To deal with the inertial problem, we need to zoom out beyond the actuator, to the leg and foot or arm and hand configuration. Initial impact with the ground will be handled with a small compliant section of the heel, accelerating a relatively small and low-inertia ankle motor. This ankle motor, as the toe approaches the ground, then applies force to accelerate the large, powerful motors at the knee, which then can control the acceleration of the robot center of mass. It’s a scaled impact approach that we believe will insulate the largest actuators from the impact, and overall, create a fluid, natural motion. It’s capturing physics we see from animals, but doing it uses approaches better suited to technology rather than biology.
Asked on X: When will Digit get wheels?
Jonathan: Digit likely won’t get wheels. But wheeled robots are absolutely in our exploratory roadmap for a family of robots that focus on being human-centric and multi-purpose. Legs are important when the robot must be dynamically stable, to lift heavy things up high, and with a narrow footprint (like working in an aisle). A foot can be placed quickly to balance, while a wheel has to accelerate itself fast to position itself under the robot – think balancing on a segway vs. on your own two feet. And, of course, legs are better for terrain, stairs and curbs and so on. Wheels are very important when you want to carry heavy things over long distances, or maintain static stability and slower movement for near-term human-adjacent operation in homes or public spaces. I believe the earliest useful in-home robots will be wheeled, statically-stable devices, not balancing legged devices, simply to address the safety challenges in the near term.
Asked on X: Question for Jonathan: what was the hardest part of getting Digit to move so naturally around people? Big fans of the work.
Jonathan: The hardest part is priorities: We know how to do the dynamics and how to create beautiful, natural gaits. And it’s especially straightforward with a smaller, lighter robot, like Cassie. Now, with Digit 5 at over 120kgs, it requires special actuators and leg configurations to get the power and strength at the same time as the natural dynamic motion. In addition, the team is so focused on customer use cases, improving manipulation capabilities, reliability, active deployments, safety, and more, that dialing in the gait dynamics just isn’t a priority and won’t be the thing keeping Digit 5 from doing its job well. This is part of why Agility and Digit 5 are special - we are focused on solving customer applications, not just doing demonstrations, and achieving dynamic locomotion will be part of that focus.
The hardest part around people was safety, and what I learned is that predictability matters more than grace. A coworker needs to know what the robot will do next. So Digit 5 is designed to detect people, react in real time and move predictably, with lights and sounds that signal its intent. That took us two years, and I still want it to move beautifully.
Asked on X: I love Cassie.
What were the trade-offs involved in transitioning from leaf springs (in Digit 3) to rigid links (incorporating torque or force sensing?) in Digit 4?
Jonathan: Leaf springs are great for handling harsh impacts during a running gait, but they add complex dynamics (and of course mechanical complexity) when you’re trying to stand and manipulate things. Cassie was optimized for walking and running; Digit is optimized for locomanipulation. And now with Digit 5, the human-style leg configuration is designed so the robot will have the ability to lift heavy things while getting low to the ground.
Asked on X: Question for Jonathan: as Digit moves toward broader deployment, which mechanical parts changed the most between versions, and which did you deliberately freeze to make production and service easier?
Jonathan: Nearly every part changed between Digit 4 and Digit 5. Digit 4 was the first commercially deployed humanoid robot, and with that time in the field, we learned so much about customer requirements. We were able to do a full, formal product design process, involving hundreds of customer requirements that translated into hundreds of engineering requirements. We retained many features and engineering solutions, but the components are nearly all different and updated. Many include new design-for-manufacture, such as sheet metal, casting, or other high-volume manufacturing processes. Digit 5 will be easier to build and easier to service because of engineering changes made based on learnings from Digit 4.
Thanks to everyone who sent questions on X and LinkedIn. We couldn't answer them all in an hour, and the ones we didn't get to will help shape what we share next about how Digit is built.
Follow Agility on X and LinkedIn to see Digit at work.